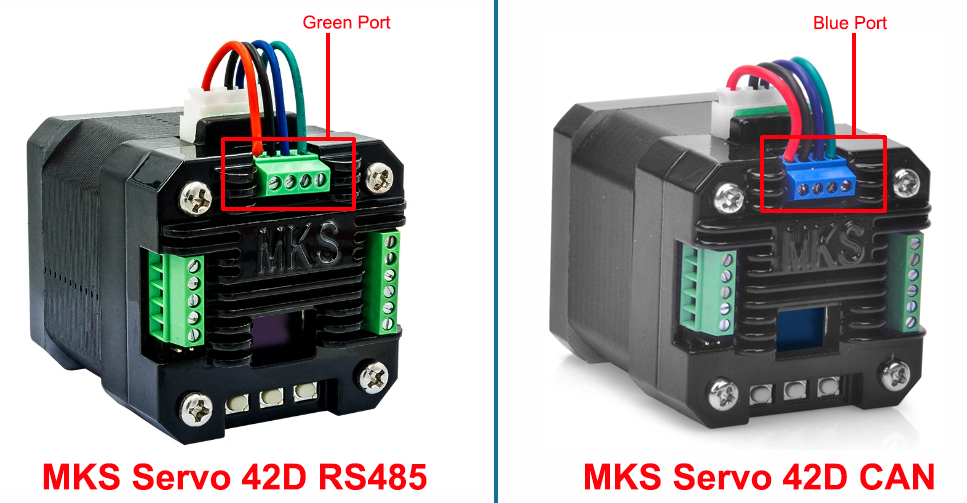
Note: there are two version of MKS servo 42D, If you get the MKS Servo 42D CAN(blue port), please visit the tutorial link: https://osoyoo.com/?p=60953
Content
Description
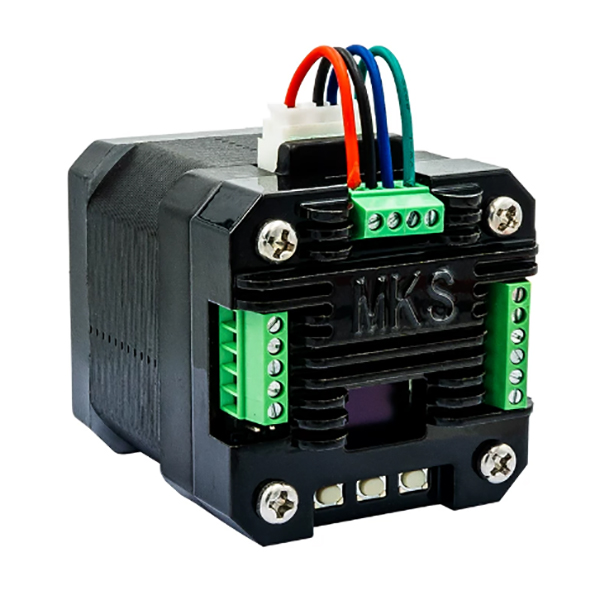
The MKS SERVO42D RS485 closed-loop stepper motor is a product independently developed by the Maker Base to meet market demands. It features a pulse interface and an RS485 interface, a built-in high-efficiency FOC vector algorithm, and a high-precision encoder. Through position feedback, it effectively prevents step loss. It is suitable for applications such as small robotic arms,3D printers, engraving machines, writing machines, automation products, and e-sports competitions.
Key Features
- Supports 6 operating modes: pulse interface (open loop, closed loop, FOC mode) and serial interface (open loop, closed loop, FOC mode);
- High-performance FOC vector control algorithm, torque, speed, and position three-loop control;
- It supports curved acceleration and deceleration, resulting in smoother motor start-up and stopping:
- Supports single-turn zeroing function, origin switch zeroing function, and mechanical limit switch zeroing function;
- Supports left and right limit functions;
- Supports direct setting of the midnight time;
- Supports both relative and absolute position control modes;
- Supports any number of subdivision steps from 1 to 256;
- Built-in 256-step subdivision interpolation algorithm, ultra- quiet motor operation, ultra-low vibration;
- Maximum input pulse frequency: l6okHz; maximum speed: 3000RPM+.
- Motor angle information is updated in real time (motor enabled or disabled);
- Onboard industrial- grade high-precision l6384-line magnetic encoder;
- 42D board has four high-power MOSFETs, 40V/20A.
- Onboard RS-485 interface, 256 slave addresses, and supports broadcast and packet addresses.
- Supports MODBUS-RTU communication protocol;
- Maximum operating current 5.2A, MOSFET continuous operating current 46A;
- Onboard OLED display and buttons allow for easy parameter modification with automatic saving and immediate effect.
- It has built-in stall protection function;
- Features encoder self-calibration function;
- One-click quick factory reset;
- High-speed performance is stable, operation is smooth and vibration-free, and emergency stop is possible;
- The integrated aluminum alloy casing provides effective heat dissipation and ensures more stable continuous high-current operation of the motor.
- Provides an open-source host computer and STM32/Arduino usage examples;
- User manual: http://osoyoo.com/picture/2023003000/RS485/RS485_User_Manual.pdf
Interface
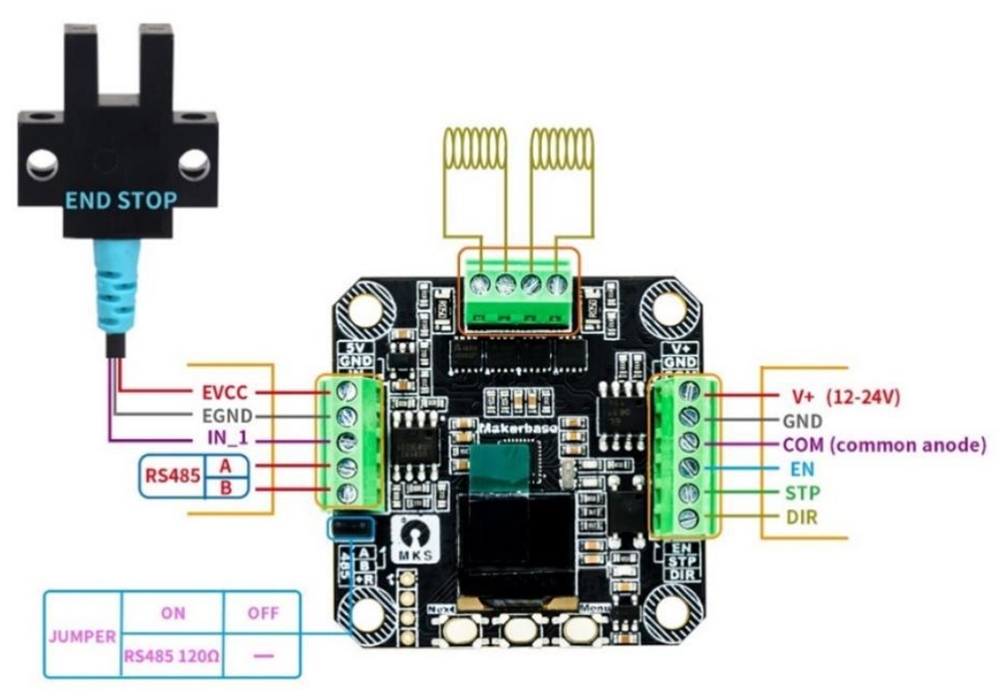
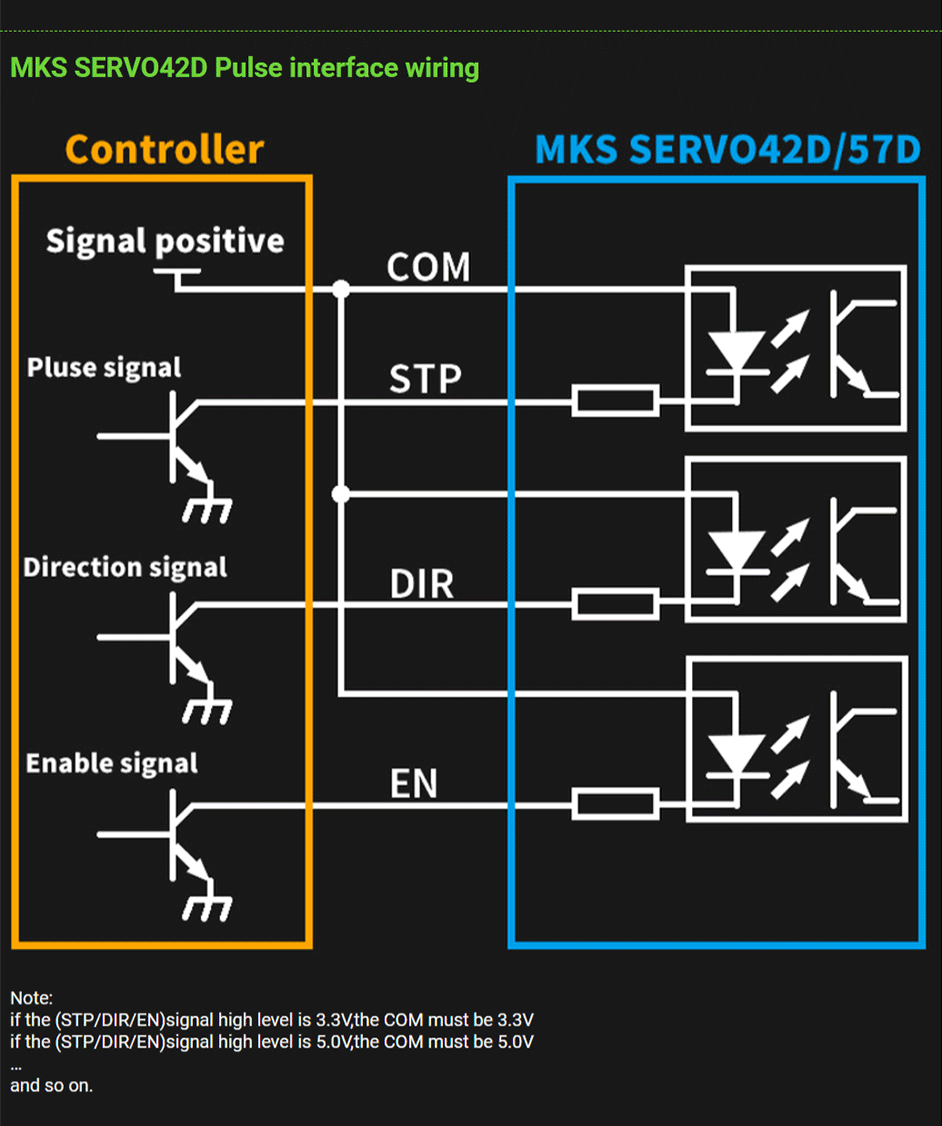
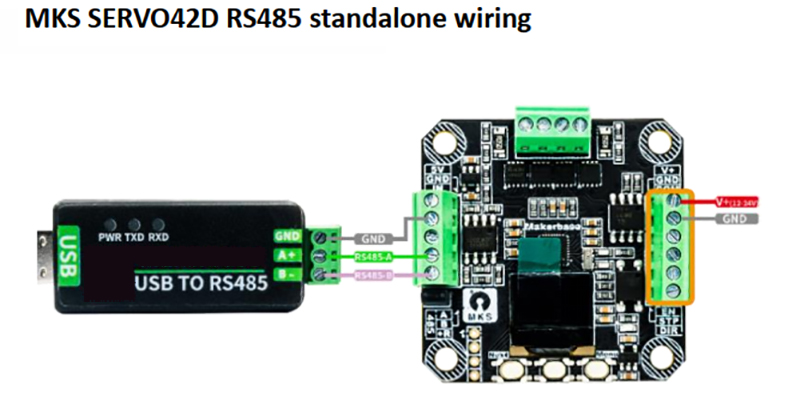
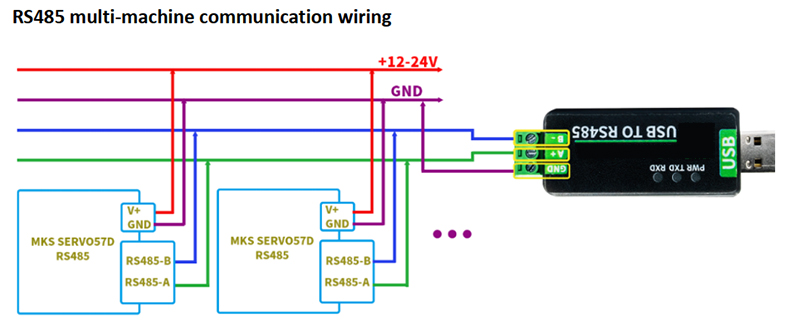
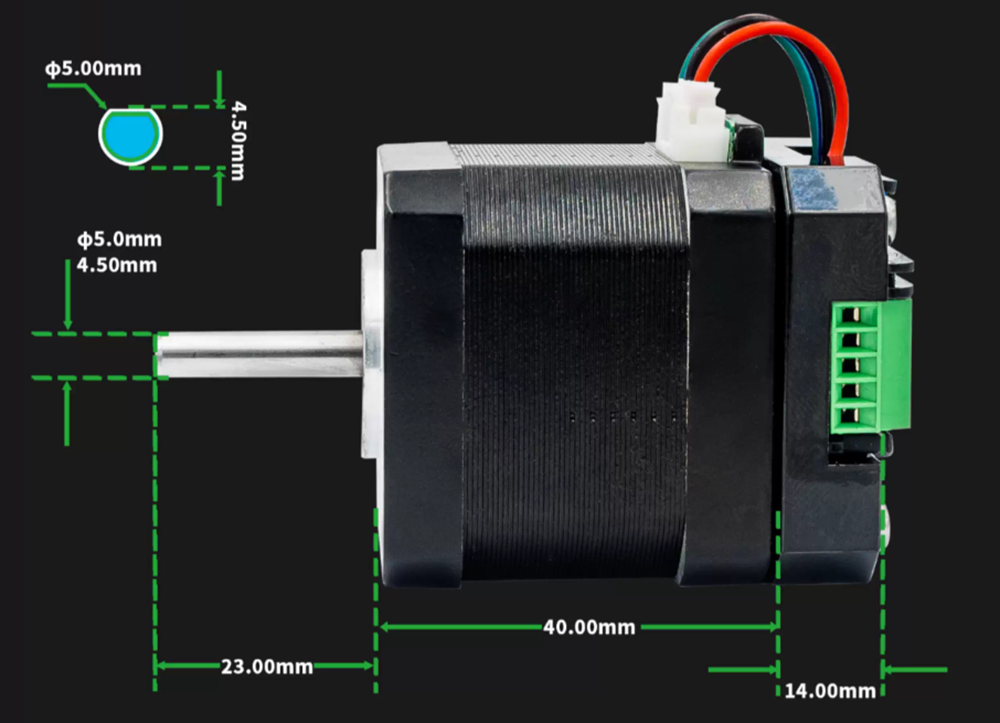
Size
FAQ
Q1: How can I reduce communication interference on the serial bus (RS485/CAN)?
A1: To minimize interference and ensure stable communication, the controller (host) and the motor must share a common ground (GND). In addition, RS485/CAN signals should be transmitted using shielded twisted-pair cables. Proper grounding and shielding significantly improve noise immunity, especially in electrically noisy industrial environments.
Q2: Why does the motor fail during initial calibration, and how can I fix it?
A2: The motor is powered by 24V, and in some cases, the initial calibration may fail under this voltage. You can resolve this issue using either of the following methods:
- Method 1: Temporarily switch the power supply to 12V to complete the calibration. After successful calibration, you can revert to 24V for normal operation.
- Method 2: When the screen displays “Press Next Key To Fixed,” press and hold the Next button for about 5 seconds until “reBoot..” appears. The motor will then restart and complete the calibration process.